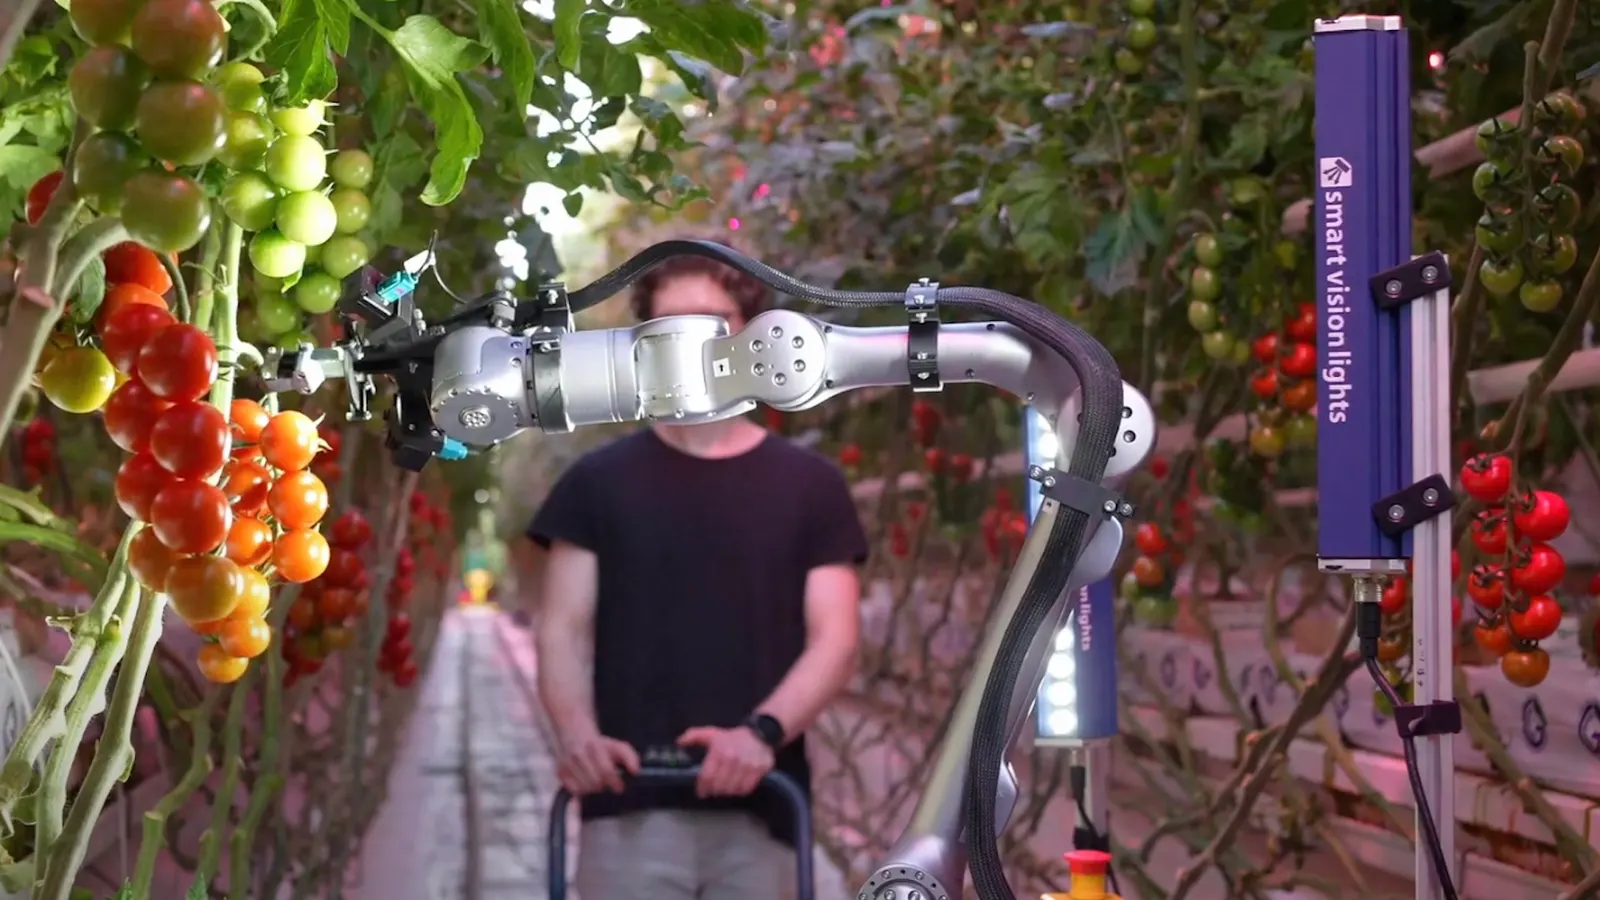
Tübingen startup building a fully autonomous truss-tomato greenhouse harvester that learns end-to-end from human demonstrations. First systems targeted for early 2027.
PRODUCT FAMILY IMAGE · MODEL APPEARANCE MAY VARYPolybot ↗
02 / UNDER THE HOOD
The useful details.
Model specifications and operating notes.
Truss tomato harvester · Latest observation
Payload—Not listed
Battery—Not listed
Runtime—Not listed
Speed—Not listed
Powertrain
Not listed
Power
Not listed
Mass
Not listed
Autonomy
Fully autonomous greenhouse harvest trained end-to-end from human demonstrations (polybot.eu). Interesting Engineering: arms ride existing grower trolley rails.
Charge time
Not listed
OPERATING NOTES
Timeline: lab start Jan 2025; first autonomous pick May; full rows December; integrated operational pilot summer 2026; first deliveries early 2027. “Fully autonomous truss tomato harvester starting 2027.”
Specifications describe this model and its listed configuration. Read operating notes for limits and qualifications. Listed figures are manufacturer or press claims, not independent verification of current availability.
Farm robots, weekly
Three farm robots, one company up close, and the week's funding and news, with sources. Free, weekly, from a farm owner. Latest issue →
Tübingen startup building a fully autonomous truss-tomato greenhouse harvester that learns end-to-end from human demonstrations. Address Maria-von-Linden-Str. 2, 72076 Tübingen. Team listed without titles: Martin Kiefel, Maike Kaufman, Claudio Michaelis, Sebastian Blaes. Advisors: Wieland Brendel, Georg Martius.
Site: lab Jan 2025, first pick May, full rows December, summer 2026 pilot, deliveries early 2027. Interesting Engineering names Martin Kiefel as co-founder.
Polybot GmbH (Maria-von-Linden-Str. 2, 72076 Tübingen) is building a fully autonomous truss-tomato harvester for greenhouses. The company website says robots learn harvesting end-to-end from humans rather than hand-coded rules, starting with high-value greenhouse crops and aiming later at more diverse farming.
Status on polybot.eu: lab development started January 2025; first autonomous greenhouse tomato pick in May; full rows harvested reliably in December; a completely integrated operational pilot planned for summer 2026; first systems to be delivered in early 2027. The homepage headline is “Fully autonomous truss tomato harvester starting 2027.”
The site lists team members Martin Kiefel, Maike Kaufman, Claudio Michaelis, and Sebastian Blaes, and advisors Wieland Brendel and Georg Martius, without job titles. Interesting Engineering’s coverage names Martin Kiefel as co-founder and says the arms ride the trolley rails growers already have.